Learning Continuous LiDAR Navigation in a Randomised Cone Maze
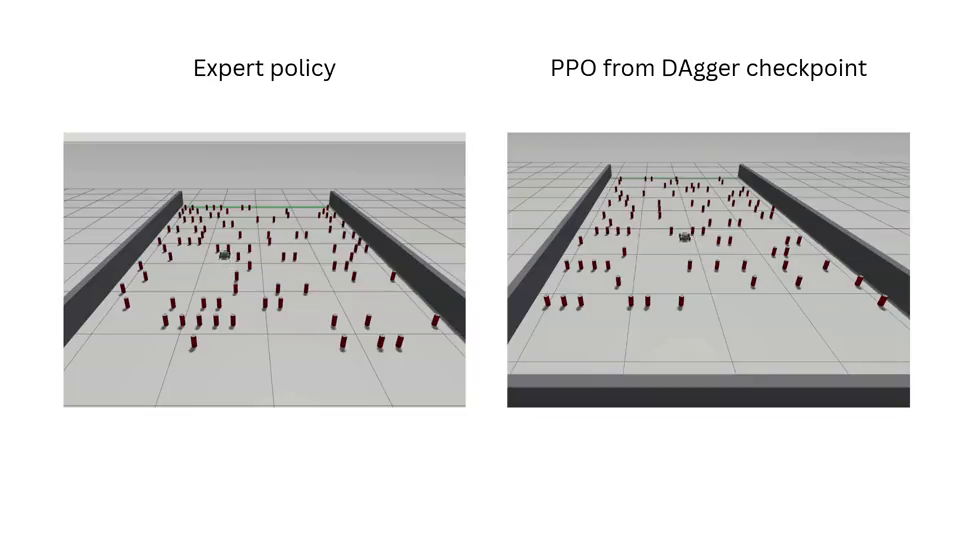
A holonomic robot learns to traverse randomised obstacle fields from a 360-degree LiDAR scan, via expert demonstration, dataset aggregation, and teacher-anchored PPO.
A holonomic robot learns to traverse randomised obstacle fields from a 360-degree LiDAR scan, via expert demonstration, dataset aggregation, and teacher-anchored PPO.
Designing and training a Convolutional Autoencoder and Vision Transformer for image inpainting.
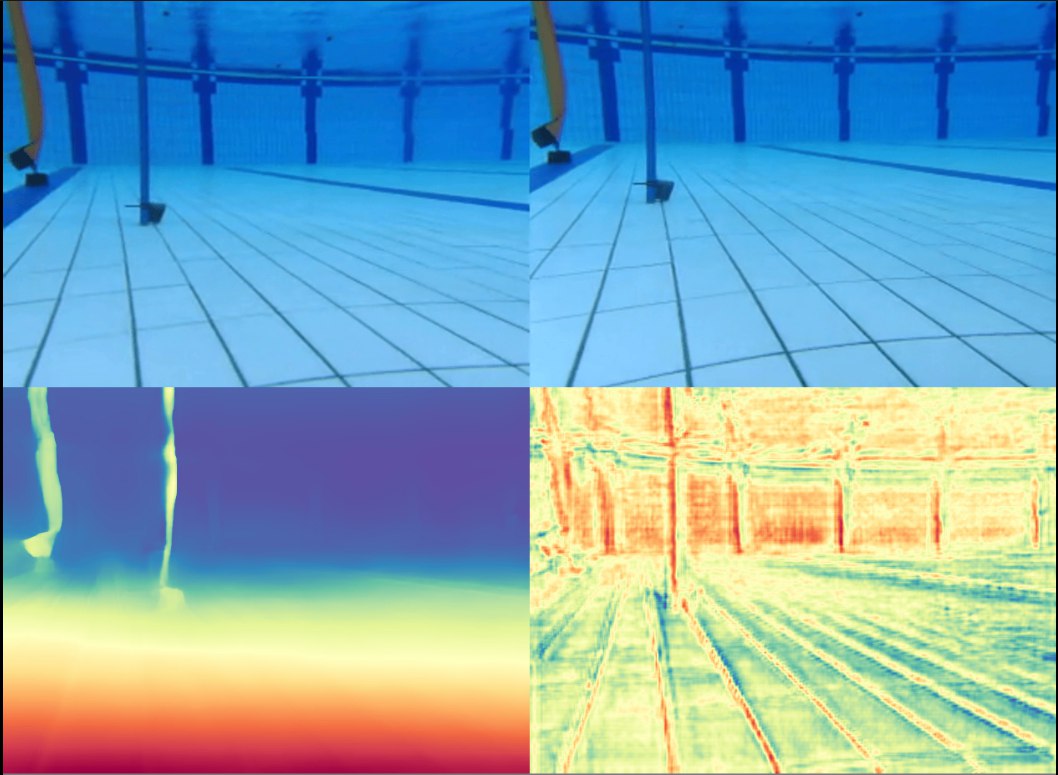
A staged investigation into stereo-based depth estimation for underwater object localization, covering classical disparity methods, deep learning inference, and empirical calibration fitting.
Machine Learning Model that can automate bed audits.
AI assistant combined with animatronic eyes and an LCD which acts as a mouth, bringing a friendly looking appearance.
Wall following robot that can navigate through a maze.
Course-traversing robot that can cross through obstacles.
No projects match that topic yet.