Autonomous Ground Robot
Course-traversing robot that can cross through obstacles.
Course-traversing robot that can cross through obstacles.
Wall following robot that can navigate through a maze.
AI assistant combined with animatronic eyes and an LCD which acts as a mouth, bringing a friendly looking appearance.
Machine Learning Model that can automate bed audits.
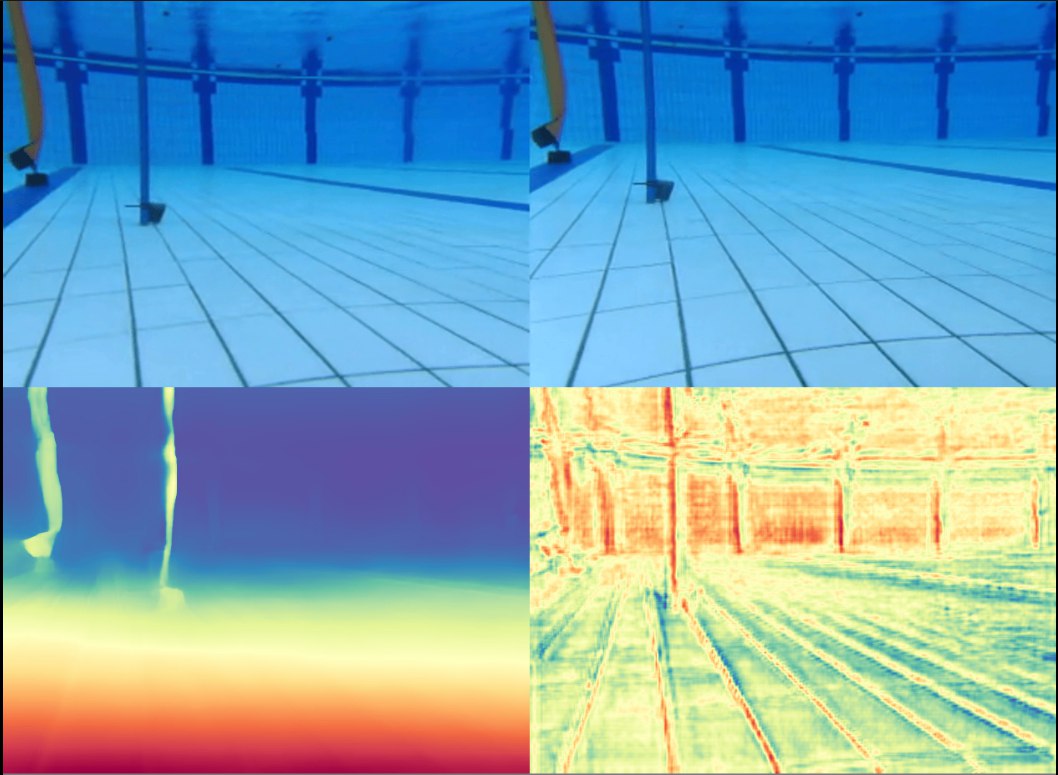
A staged investigation into stereo-based depth estimation for underwater object localization, covering classical disparity methods, deep learning inference, and empirical calibration fitting.
Designing and training a Convolutional Autoencoder and Vision Transformer for image inpainting.
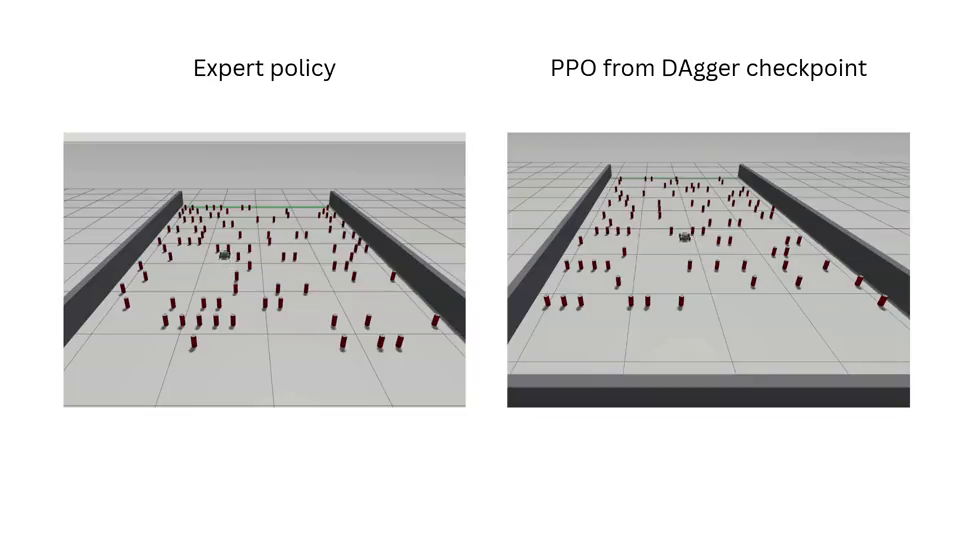
A holonomic robot learns to traverse randomised obstacle fields from a 360-degree LiDAR scan, via expert demonstration, dataset aggregation, and teacher-anchored PPO.